01 · AI & Automation
AI Assistant
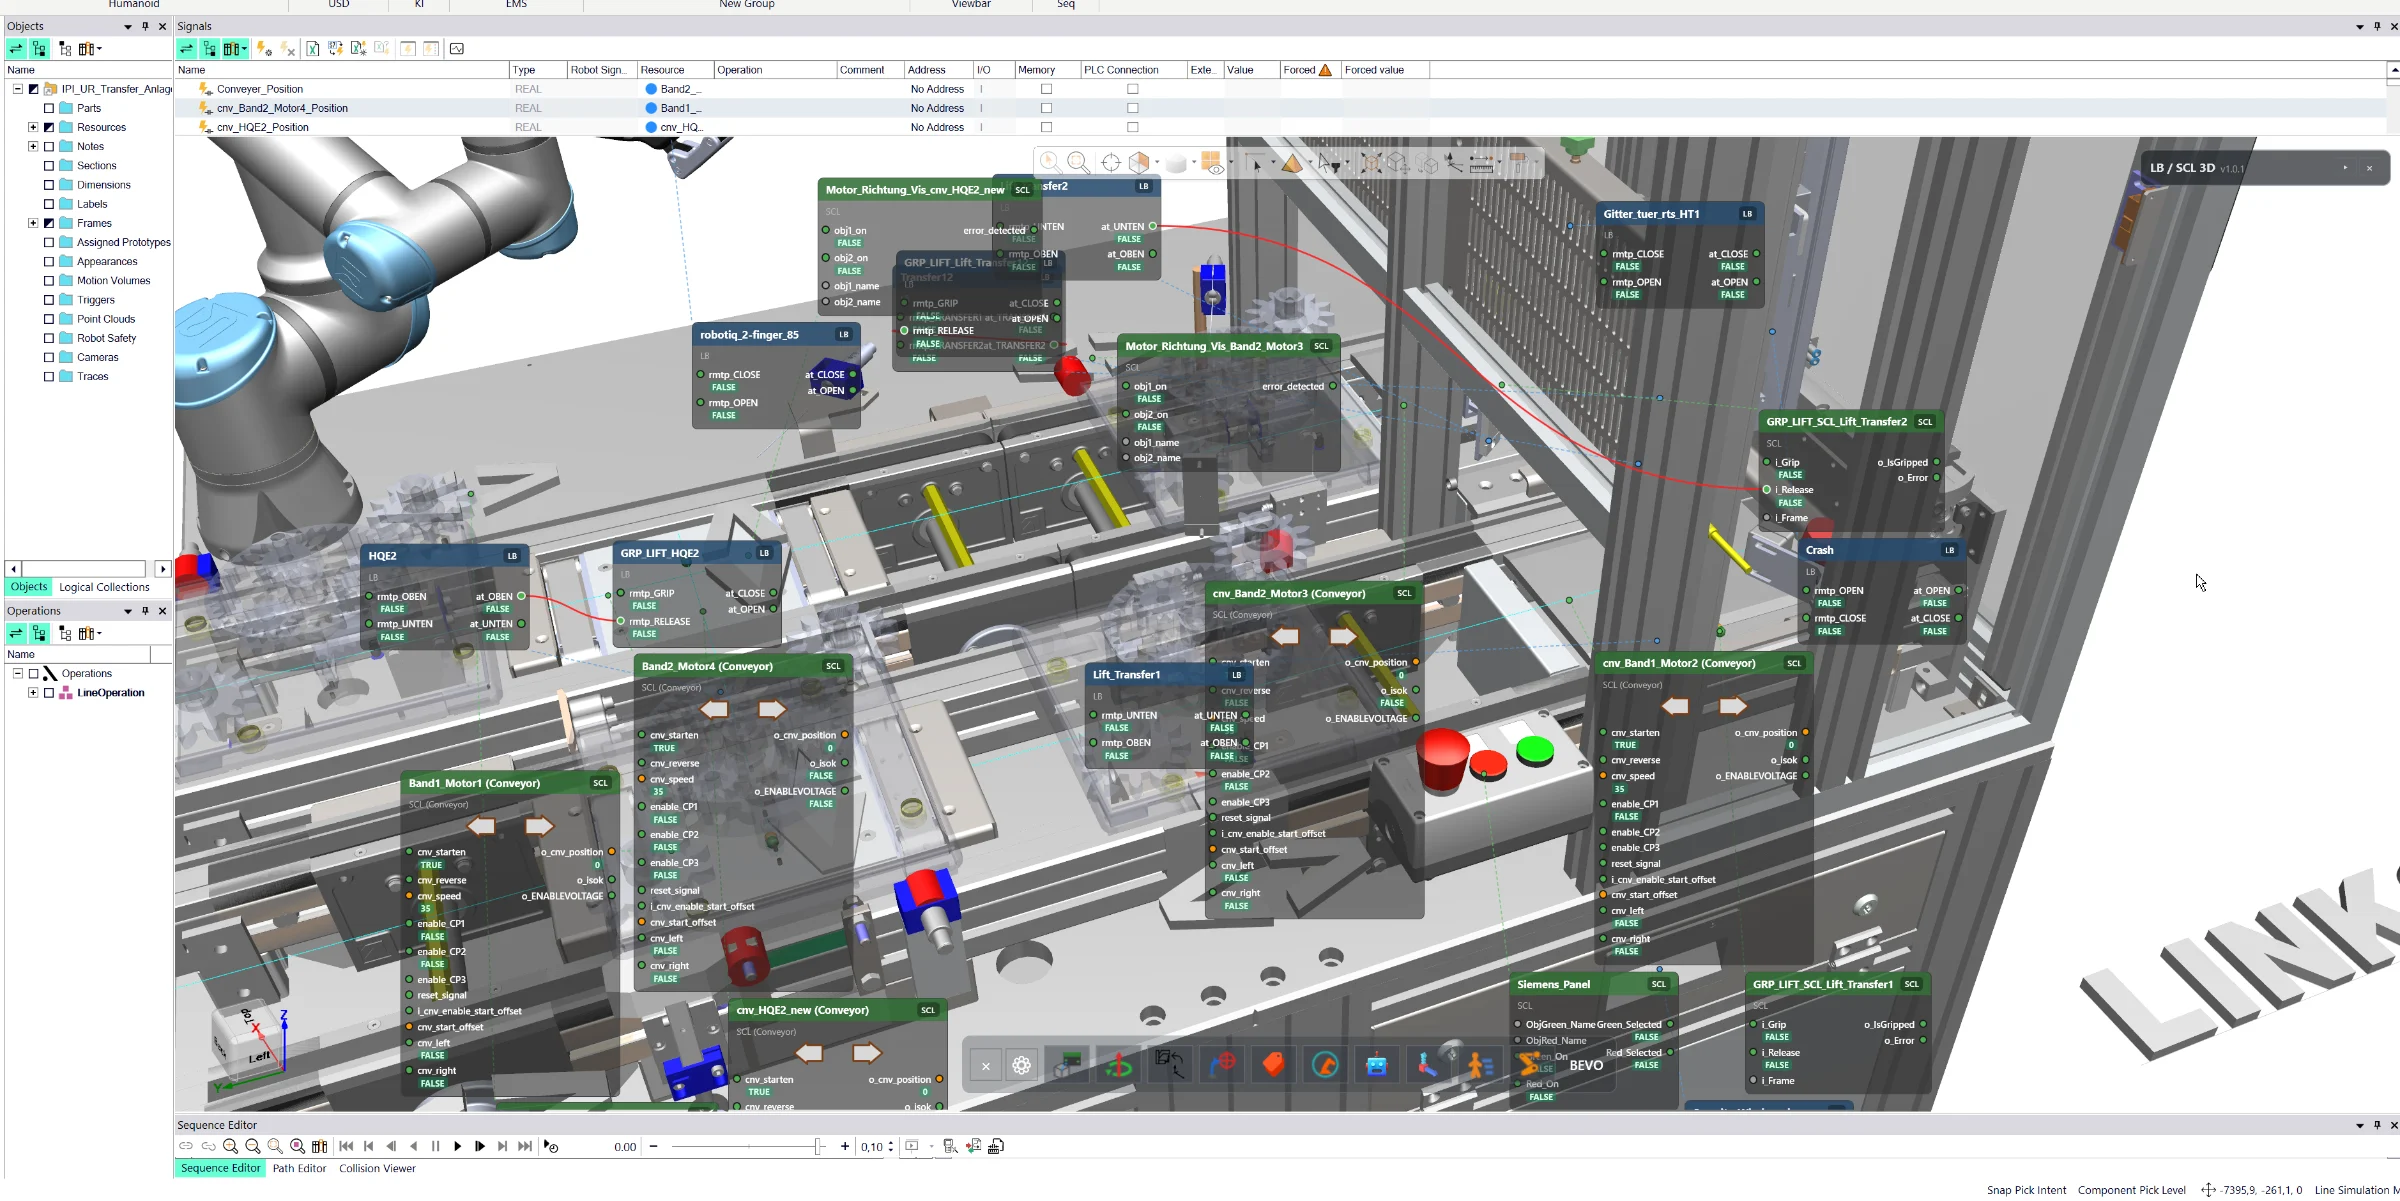
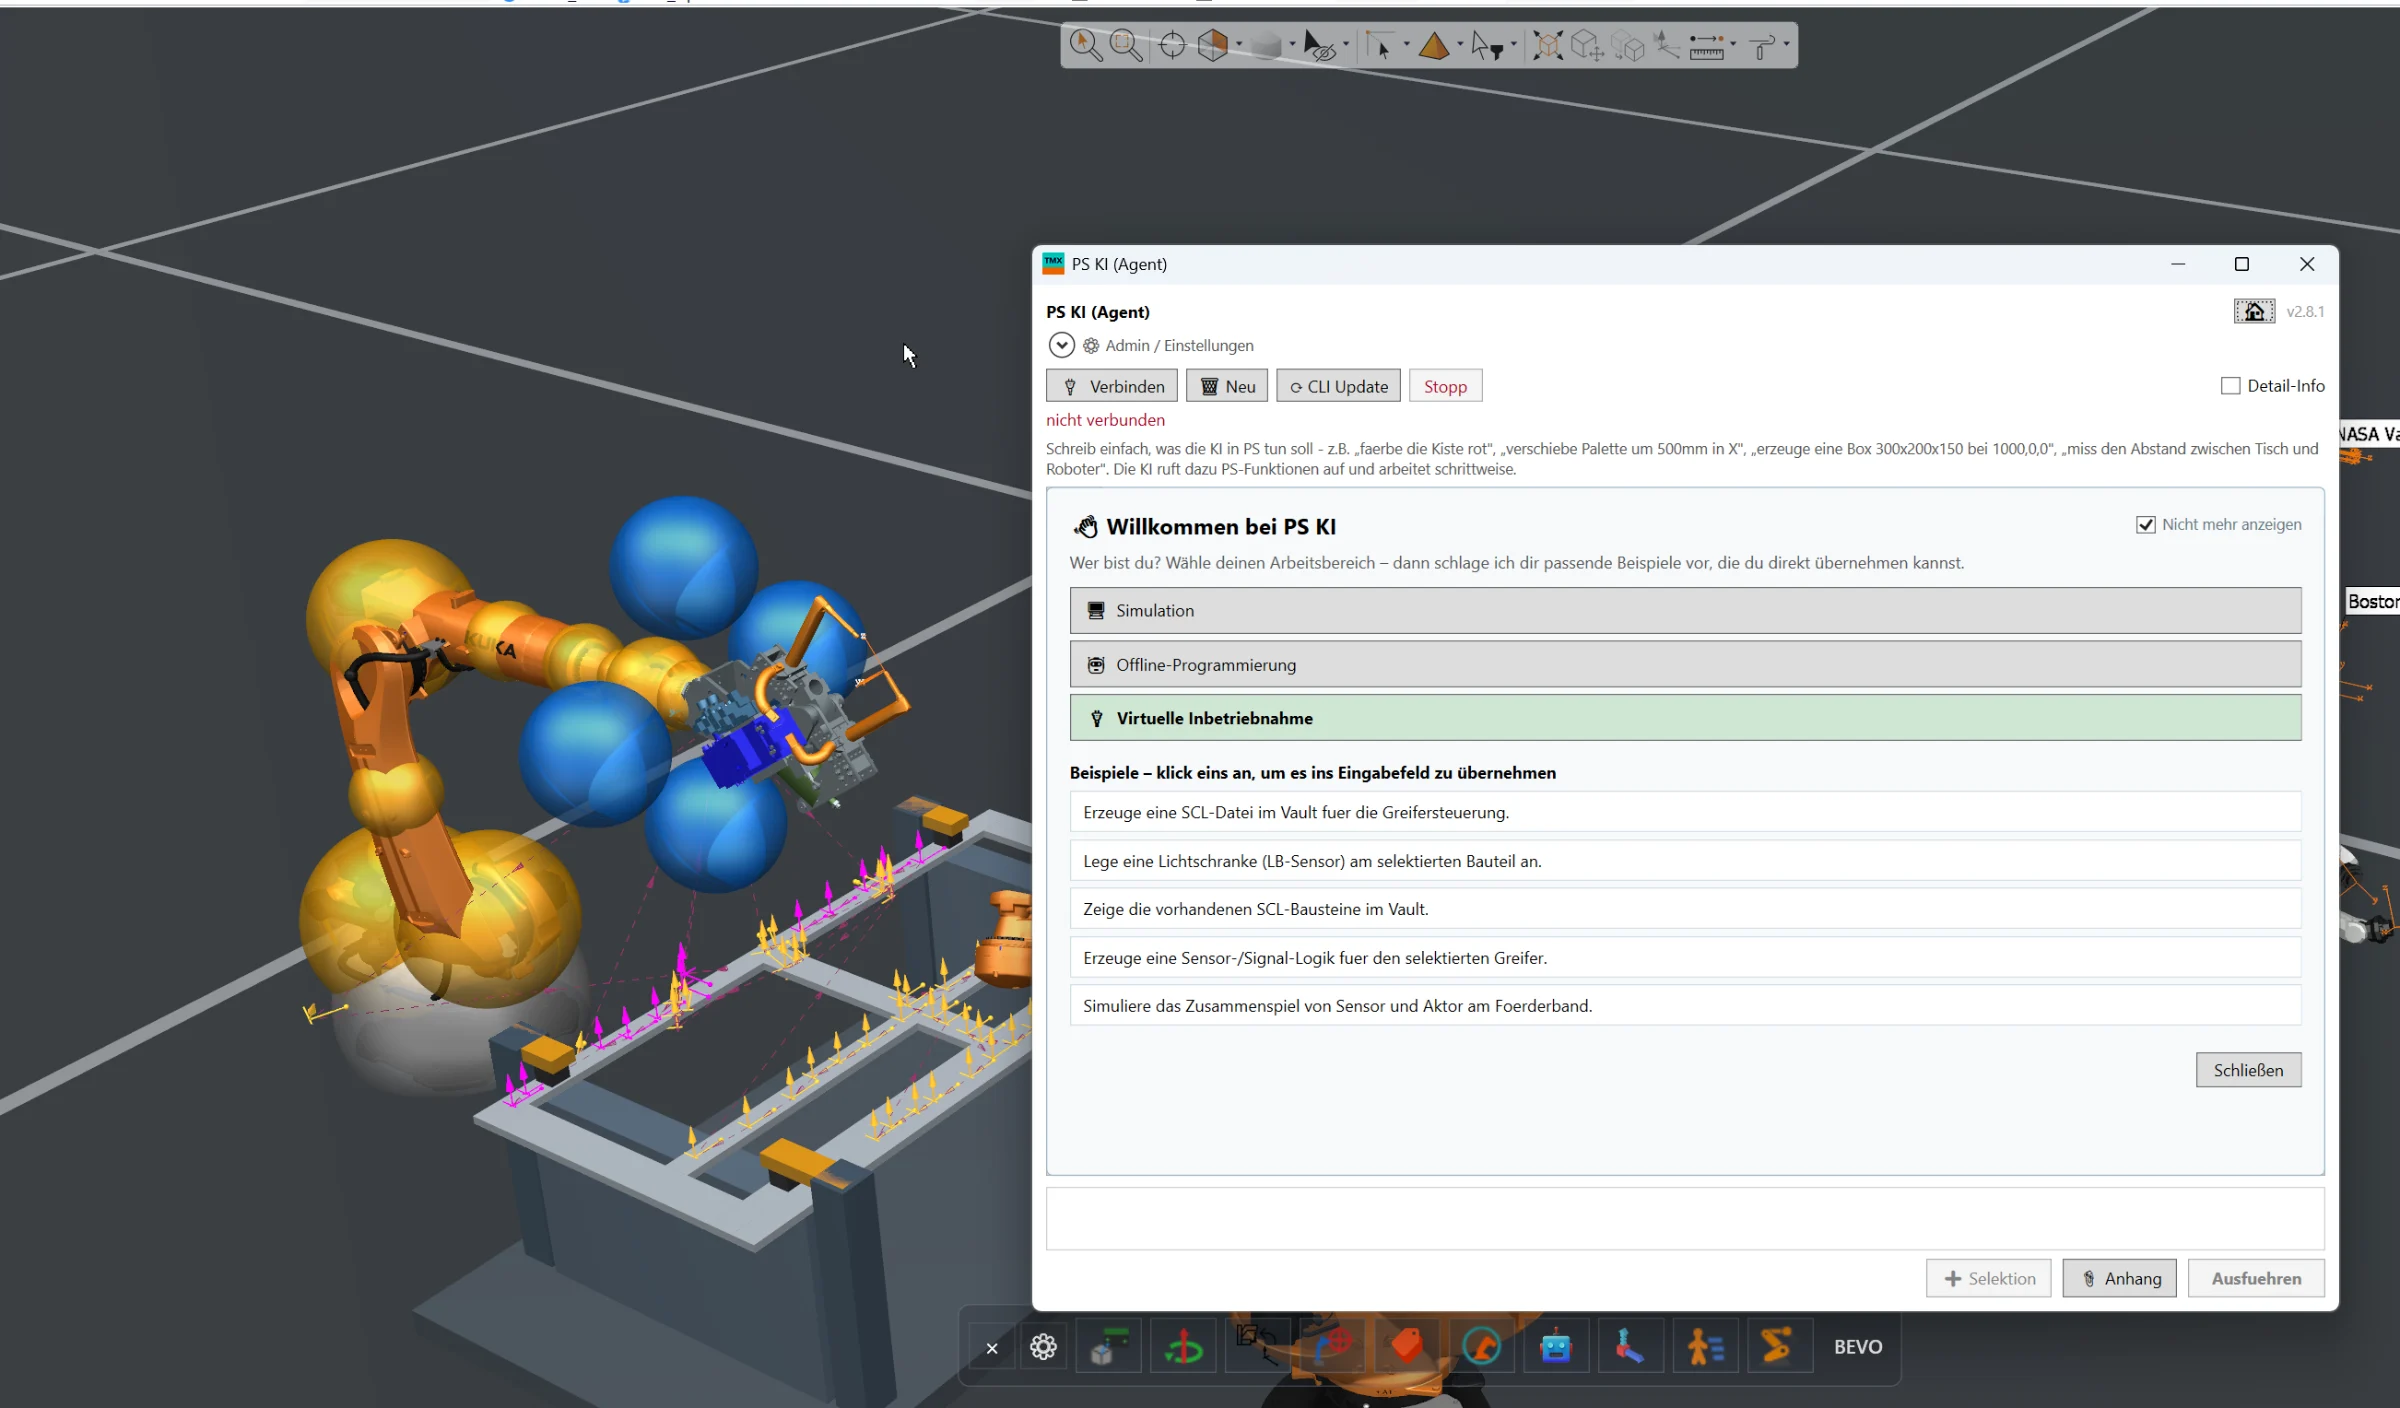
Full AI integration directly inside Siemens Process Simulate for engineering automation, simulation assistance, offline programming and virtual commissioning workflows.
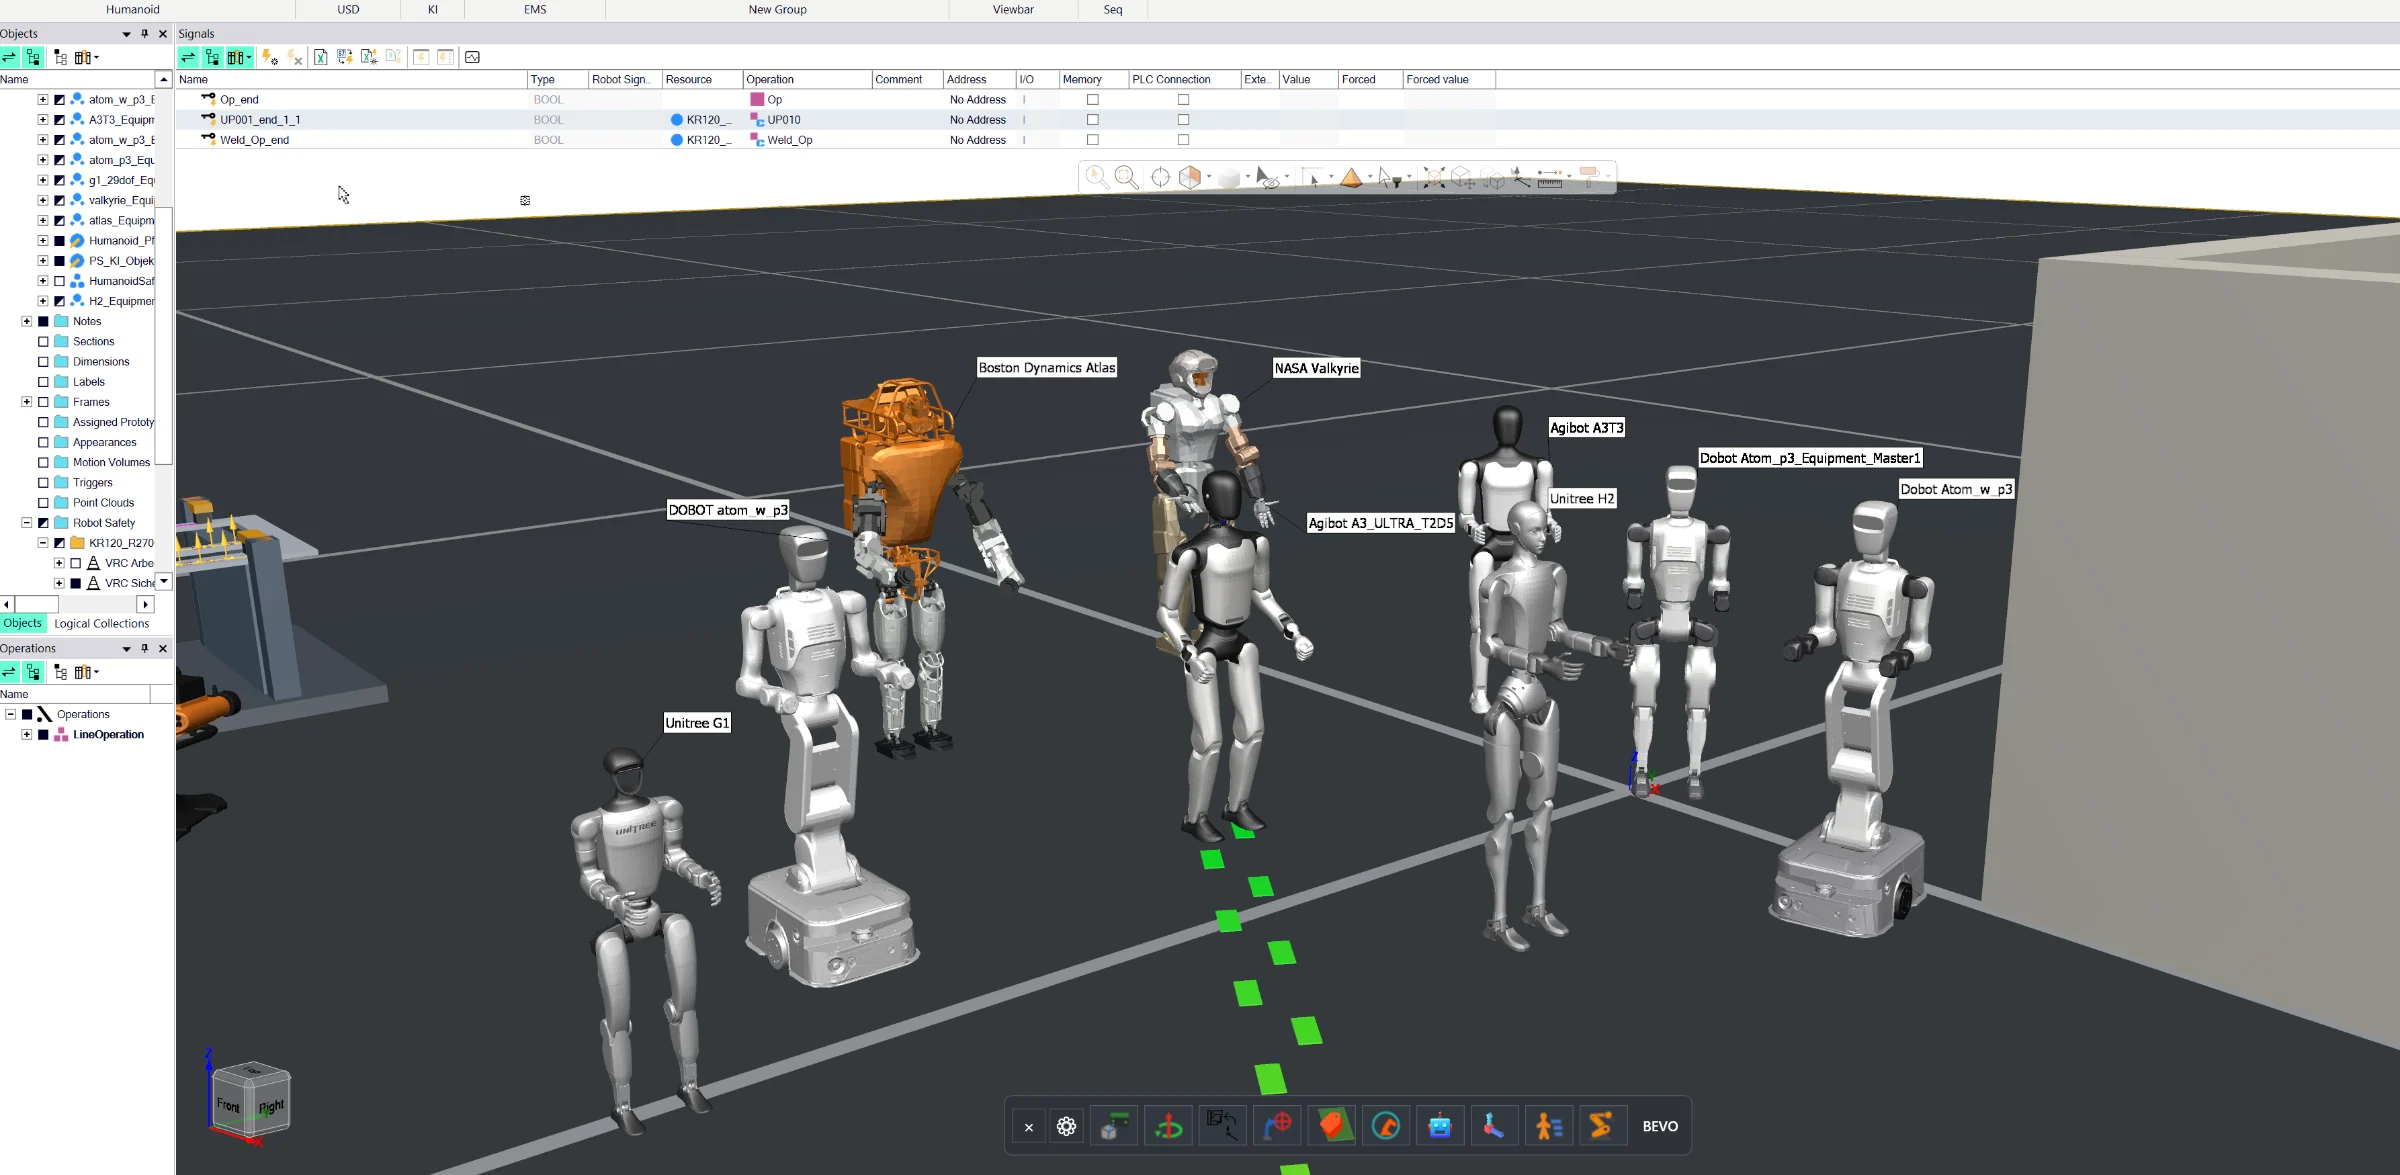
Complete humanoid engineering workflow for Siemens Process Simulate, including URDF import, walk-path definition, task-oriented programming, reachability analysis, collision-free motion planning and NVIDIA HALOS-based safety validation concepts.
Humanoid Simulation & HALOS Safety is a comprehensive engineering toolset for integrating, programming and validating humanoid robots directly inside Siemens Process Simulate.
The workflow starts with the import of humanoid robot models using URDF files. The imported kinematic structure can then be prepared for simulation and used as the basis for humanoid motion, task planning and engineering workflows.
A dedicated Walk-Step Assistant allows users to define where the humanoid should move directly inside the 3D environment. Instead of manually programming individual walking trajectories, the engineer can simply select target positions or waypoints inside the Process Simulate viewer.
For higher-level task creation, the Humanoid Task Builder provides a wizard-based workflow. The user selects the humanoid robot and defines what the robot should do rather than manually programming individual joints or complex motion sequences.
Typical task commands can include:
- Walk to a defined position
- Pick an object with the left arm
- Pick an object with the right arm
- Place or transport objects
- Perform palletizing tasks
- Climb stairs
- Sit down or change posture
- Move arms or execute predefined body motions
- Execute customer-specific humanoid operations
The objective is to make humanoid engineering task-oriented. The user does not need detailed knowledge of the robot's individual joints, kinematics or low-level motion programming. The system translates the selected task into the required humanoid operations and motion sequences.
An integrated Reach Map can be used to analyze whether relevant positions and objects can be reached by the humanoid's arms. This allows manipulation tasks and workstation layouts to be evaluated before detailed programming.
Collision-free motion planning supports the automatic generation and validation of paths while considering the humanoid robot, surrounding equipment and the simulated environment.
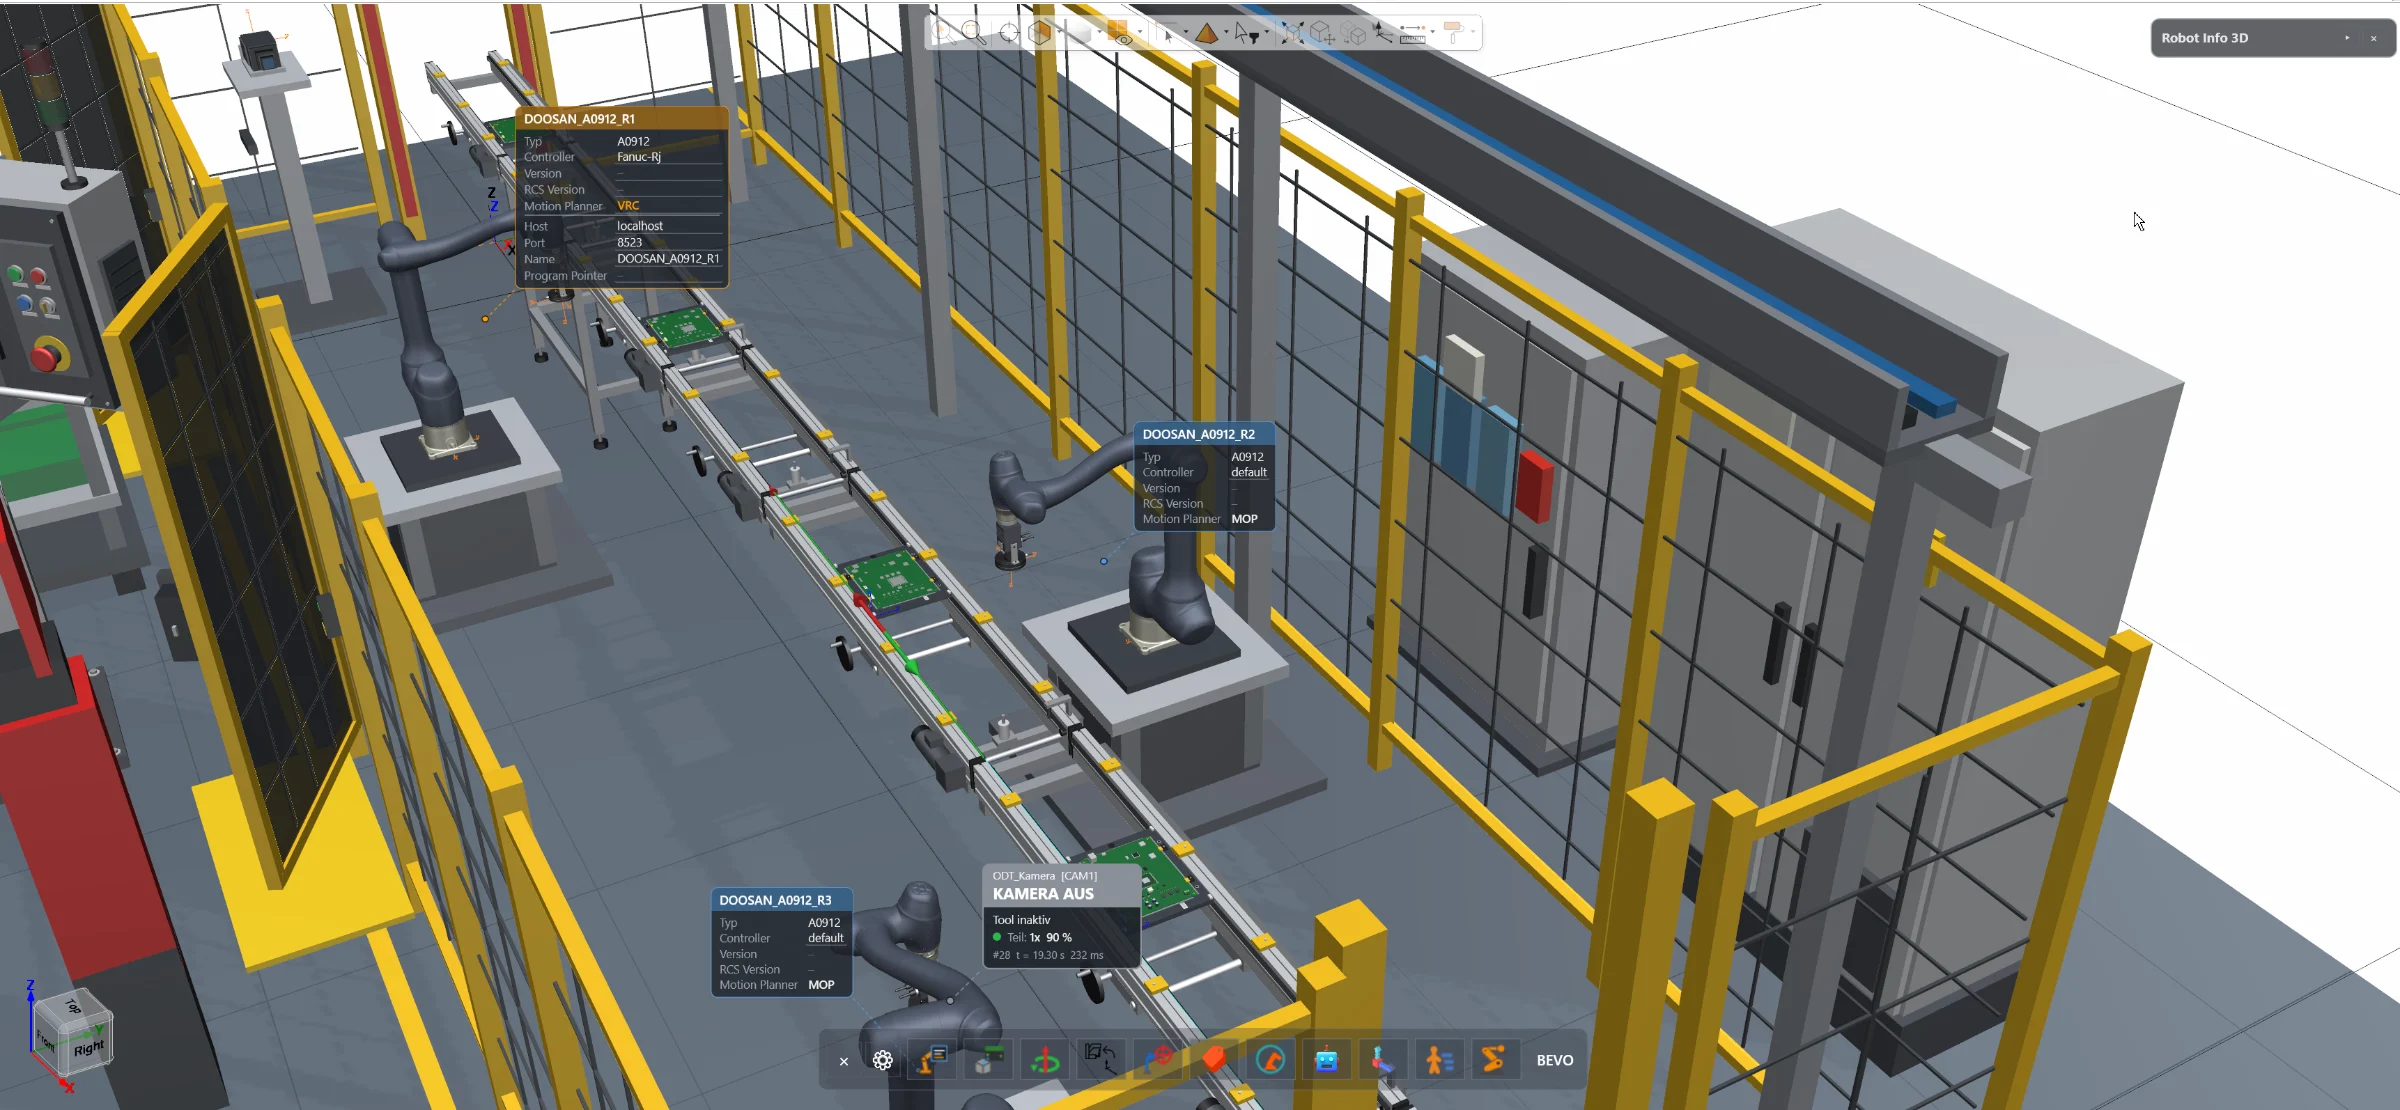
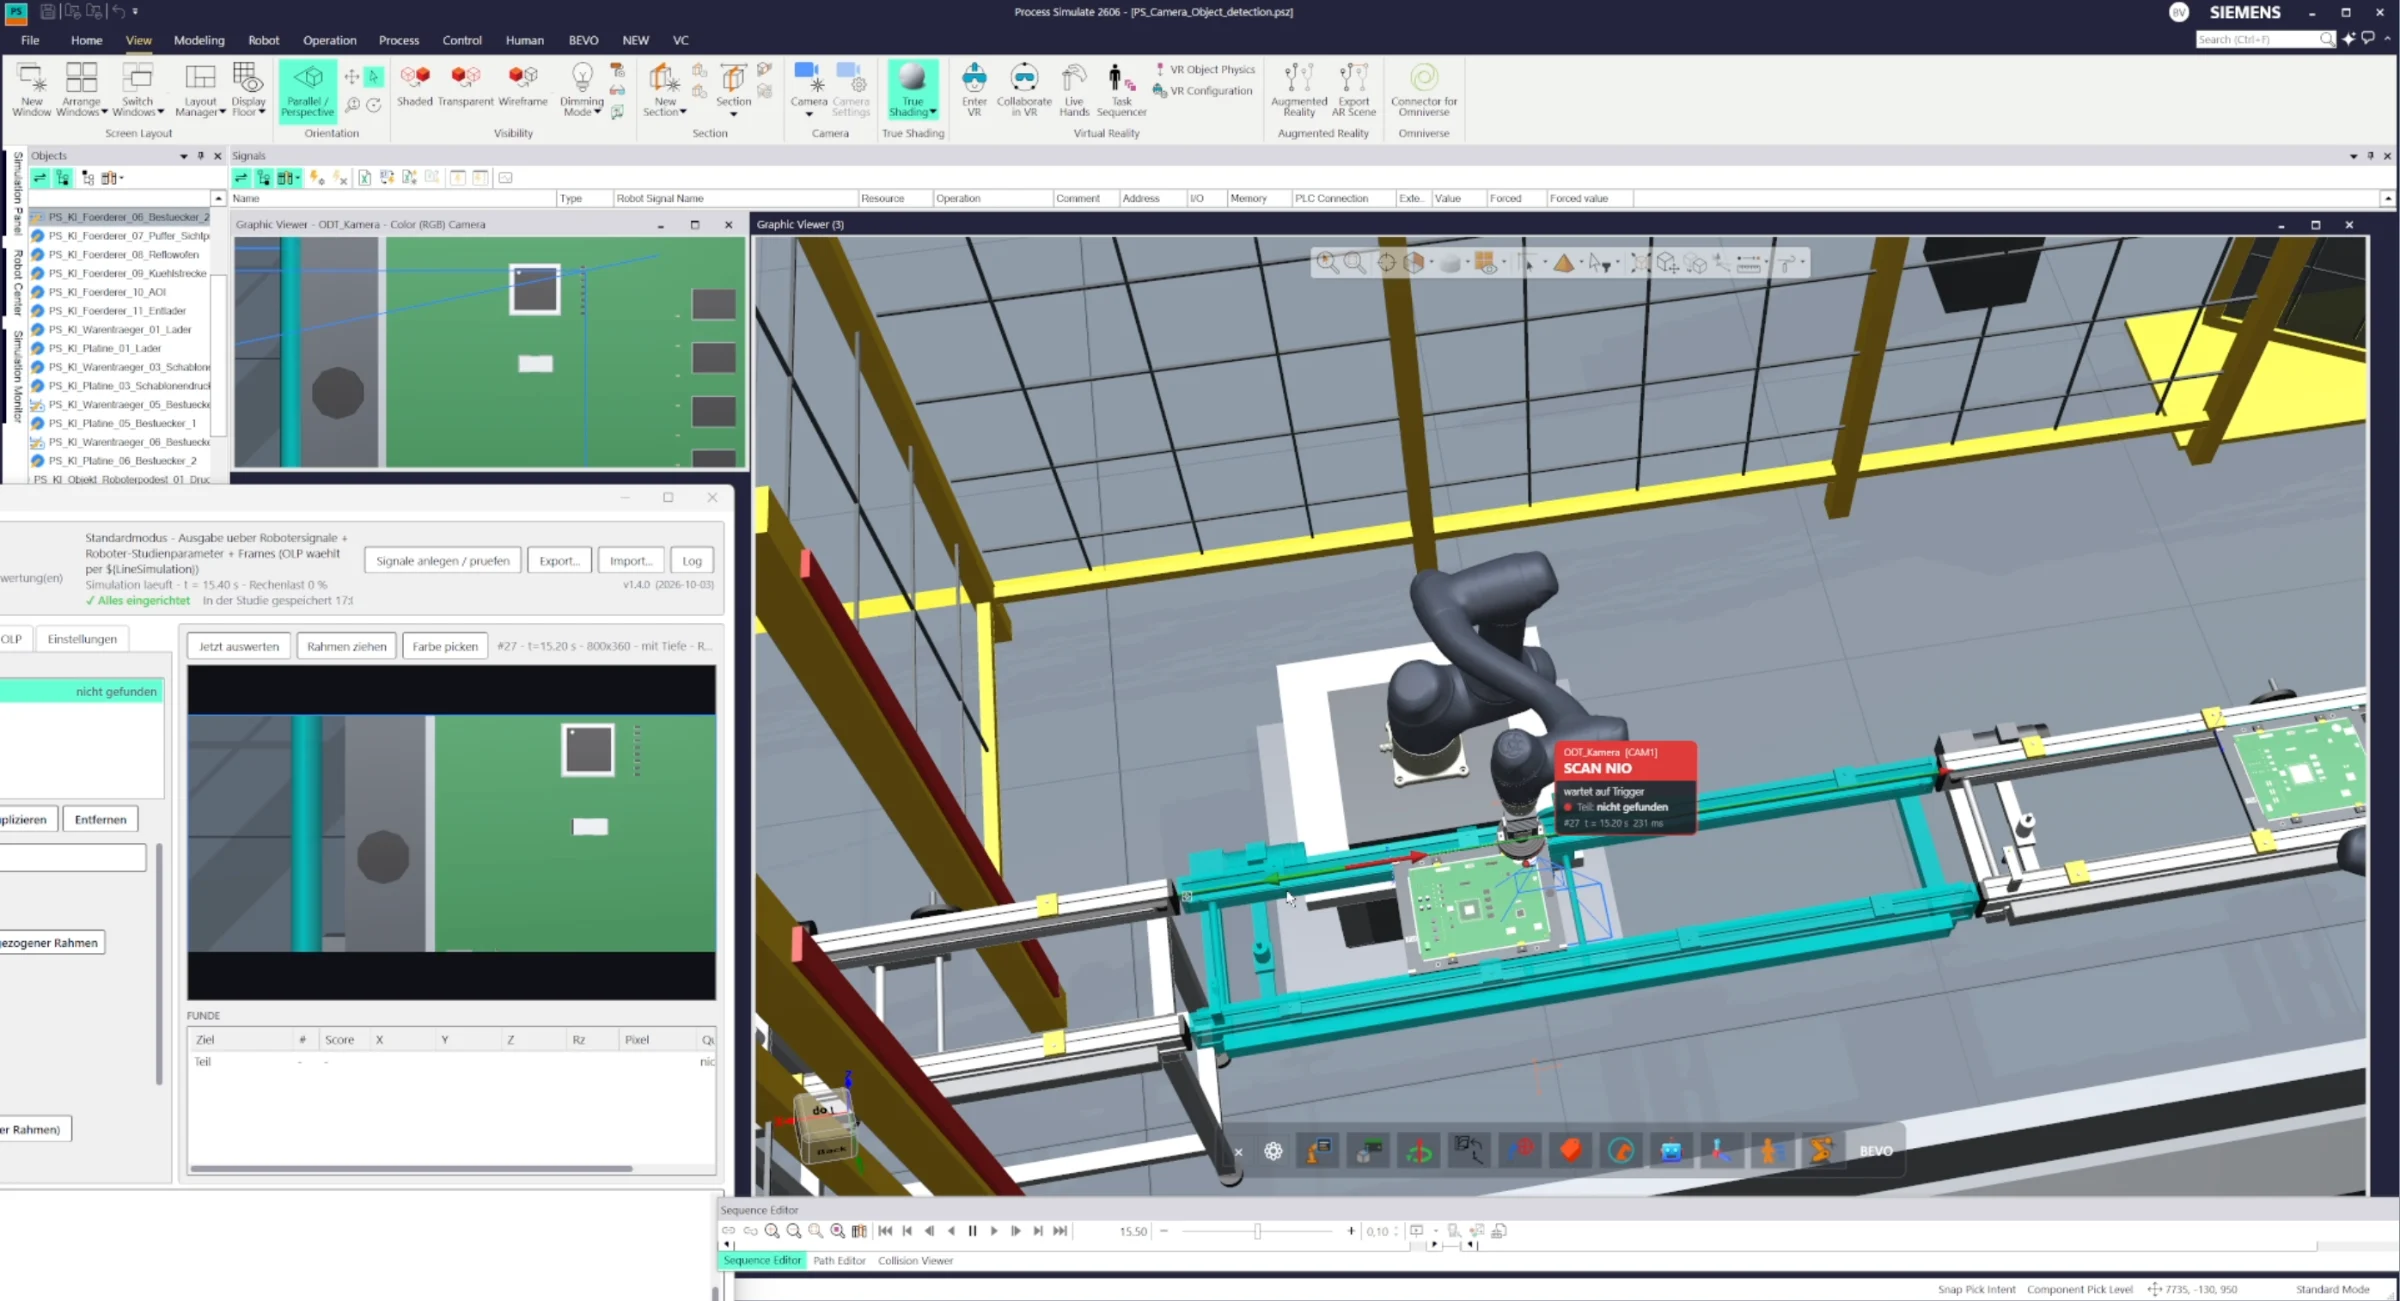
Safety validation is integrated into the same humanoid workflow using NVIDIA HALOS-based safety concepts. Safety zones, distance monitoring and camera-based observation scenarios can be included in the simulation to analyze the interaction between the humanoid robot, people and its environment.
This makes it possible to evaluate scenarios such as:
- Minimum-distance monitoring
- Safety and warning zones
- Human-humanoid interaction areas
- Camera-monitored working areas
- Movement restrictions based on safety conditions
- Warning and stop scenarios
- Validation of humanoid behavior within defined safety concepts
The complete solution combines humanoid model import, task-oriented programming, walking workflows, reachability analysis, motion planning and safety validation in one Process Simulate environment.
The exact robot models, available tasks, motion-planning functions and safety concepts can be adapted to the specific humanoid platform, production environment and customer requirements.
Full AI integration directly inside Siemens Process Simulate for engineering automation, simulation assistance, offline programming and virtual commissioning workflows.
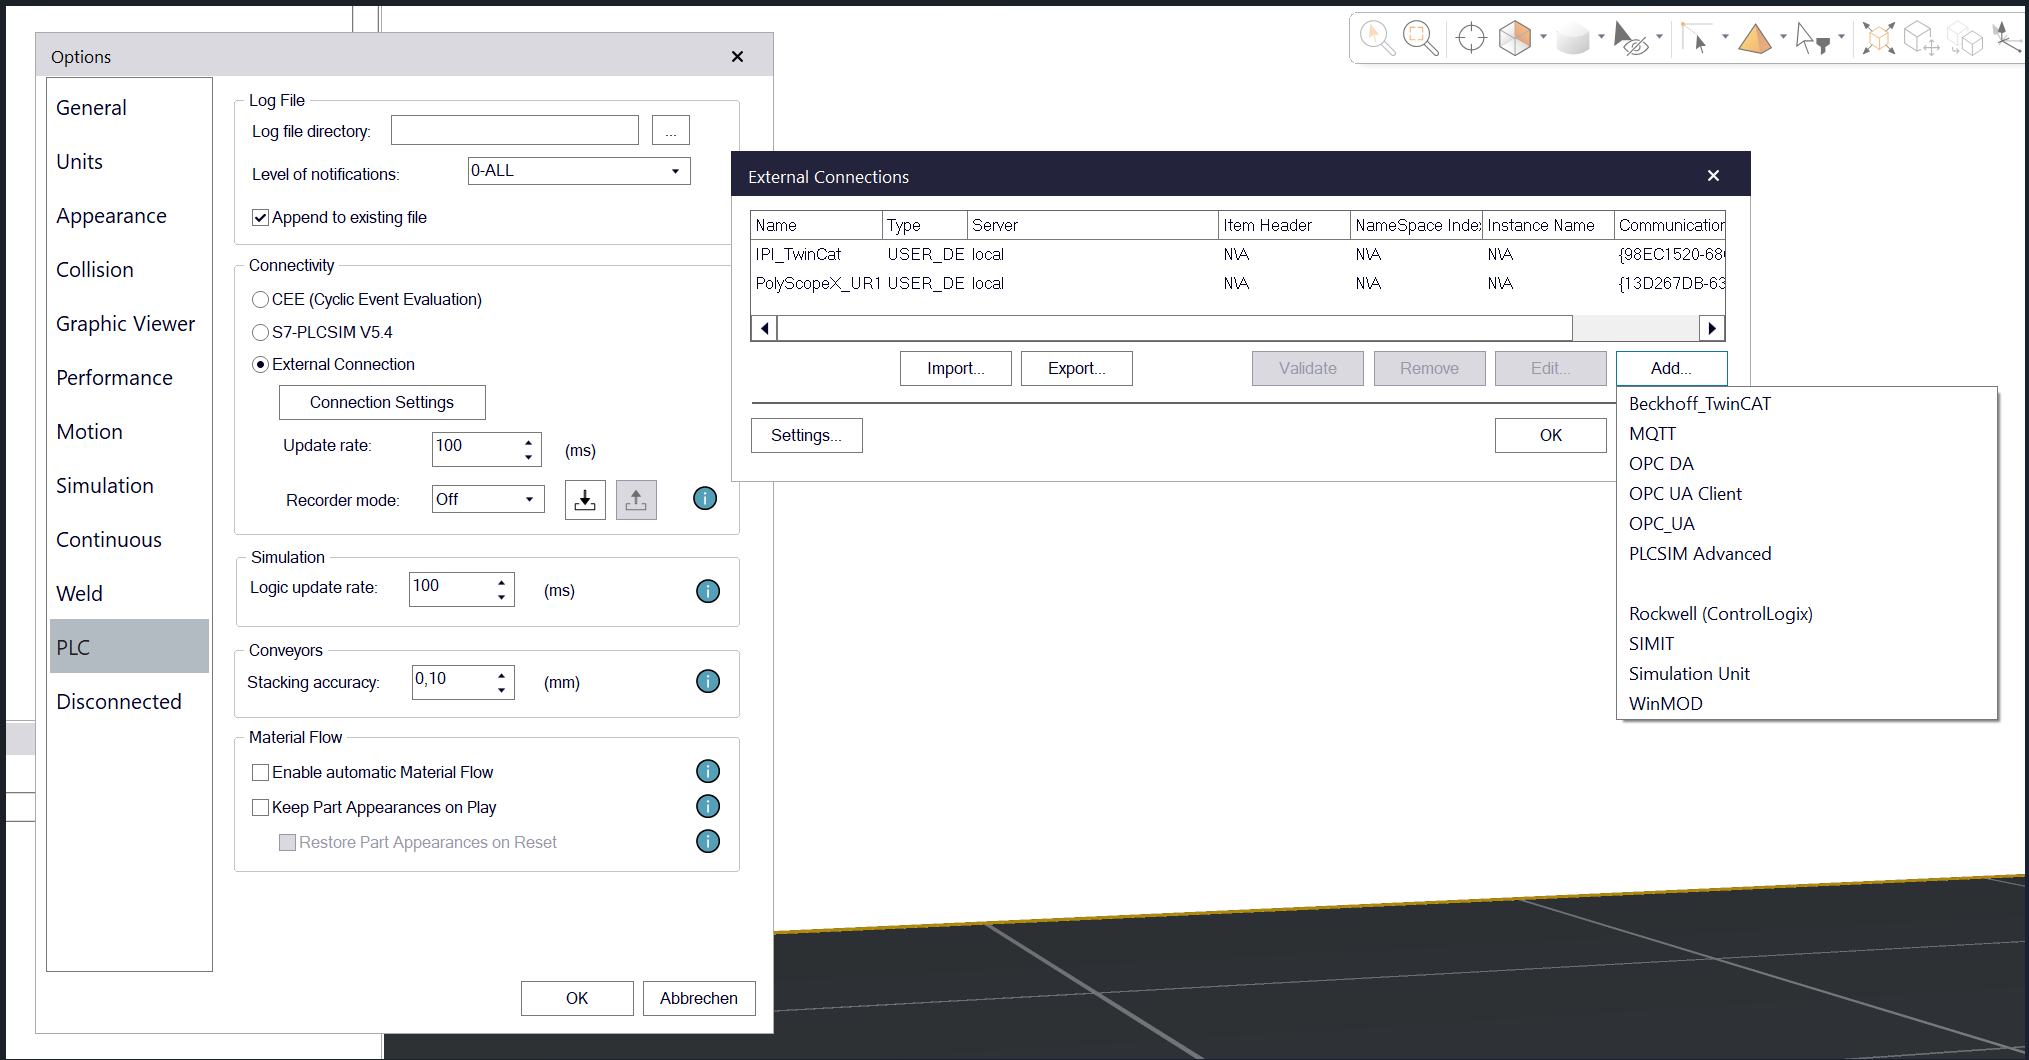
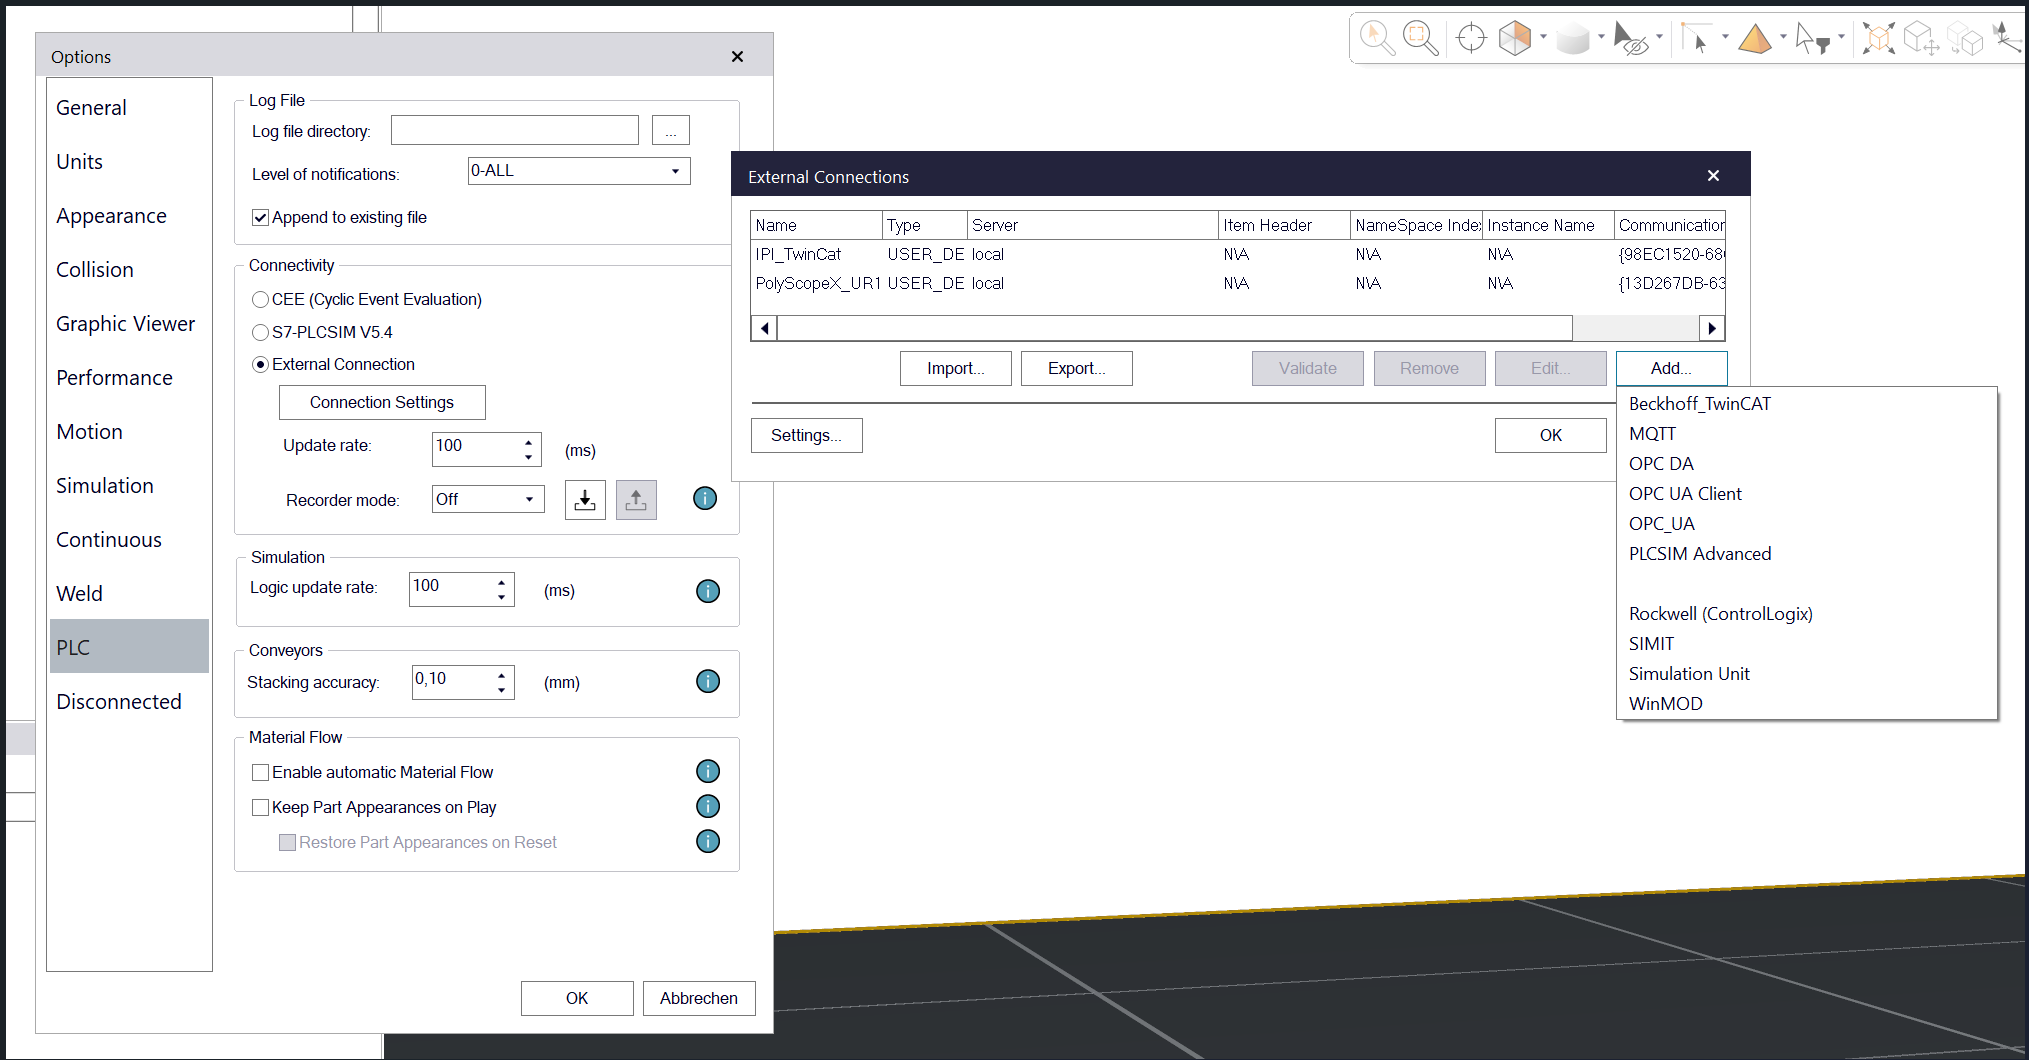
MQTT connectivity directly inside Siemens Process Simulate for exchanging simulation data, machine states, events and project information with external systems and applications.
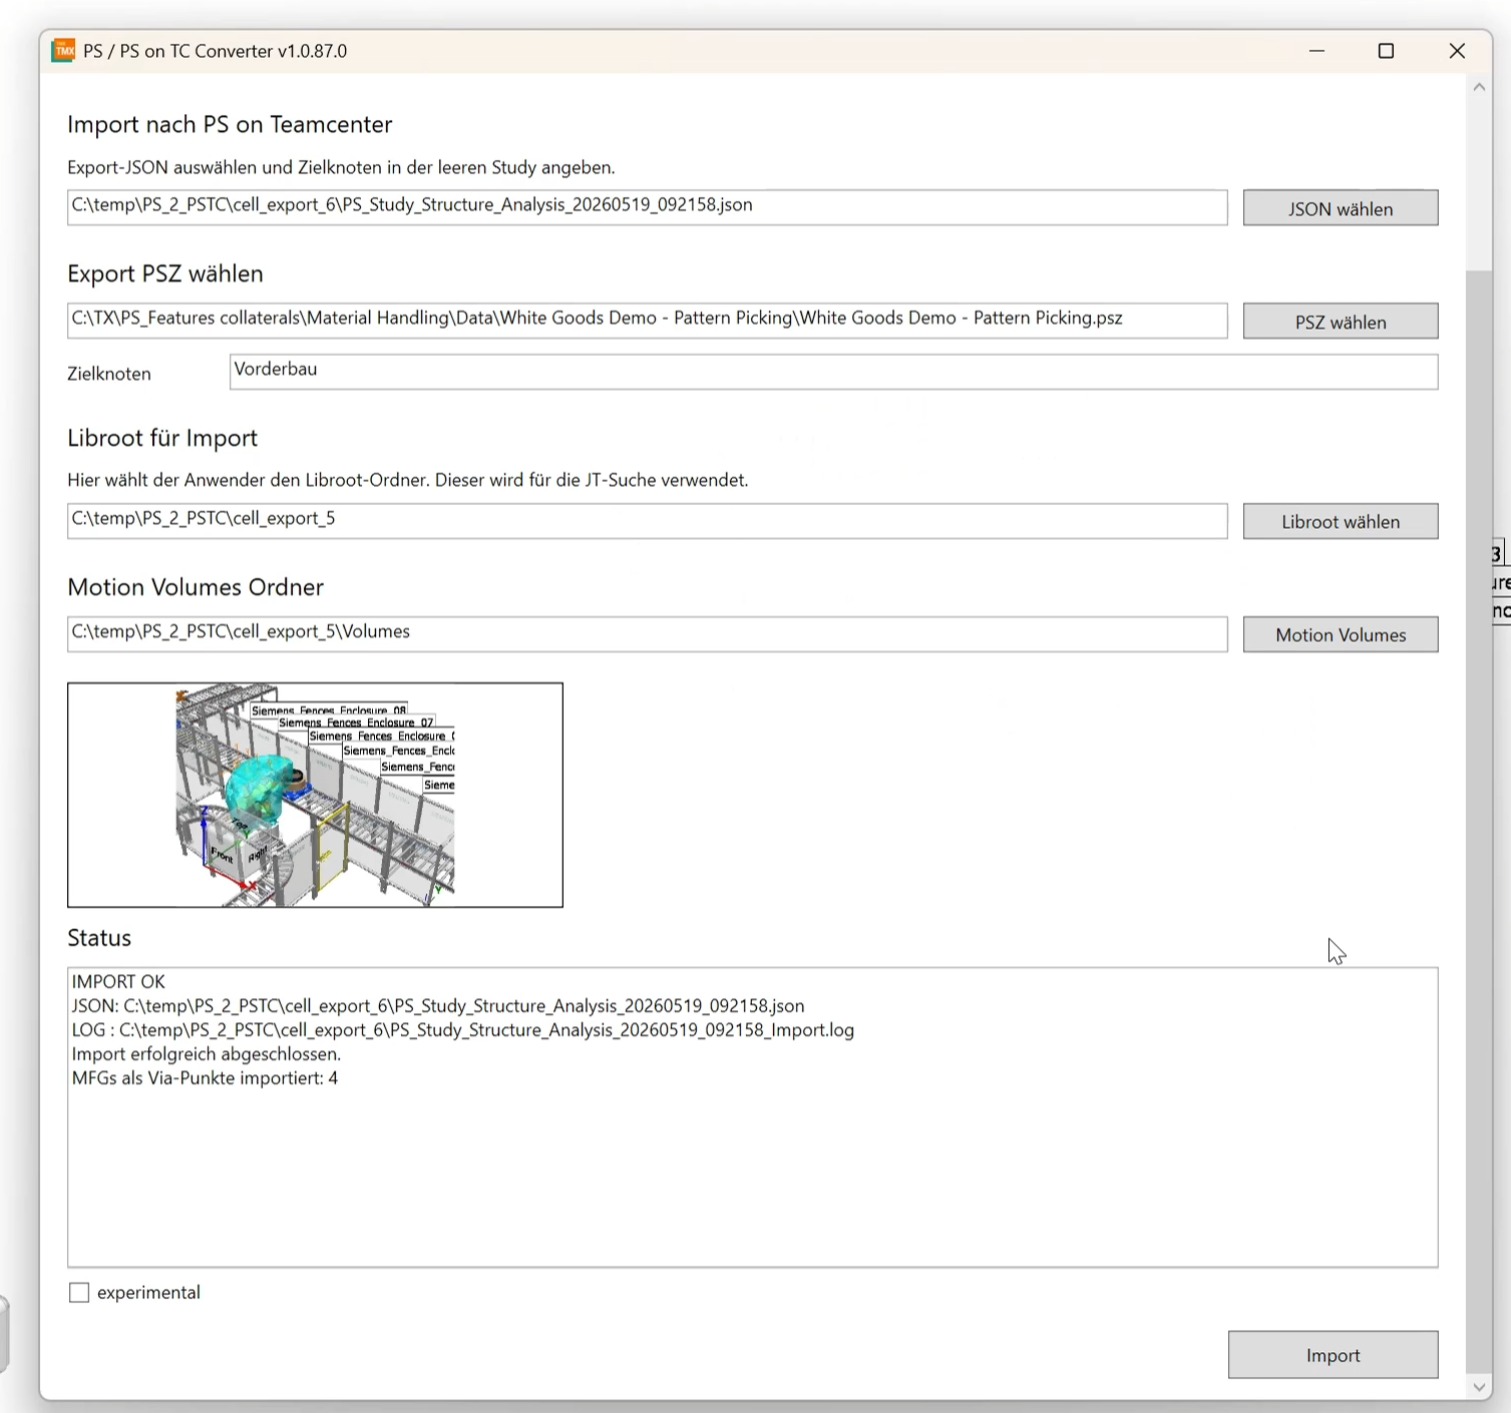
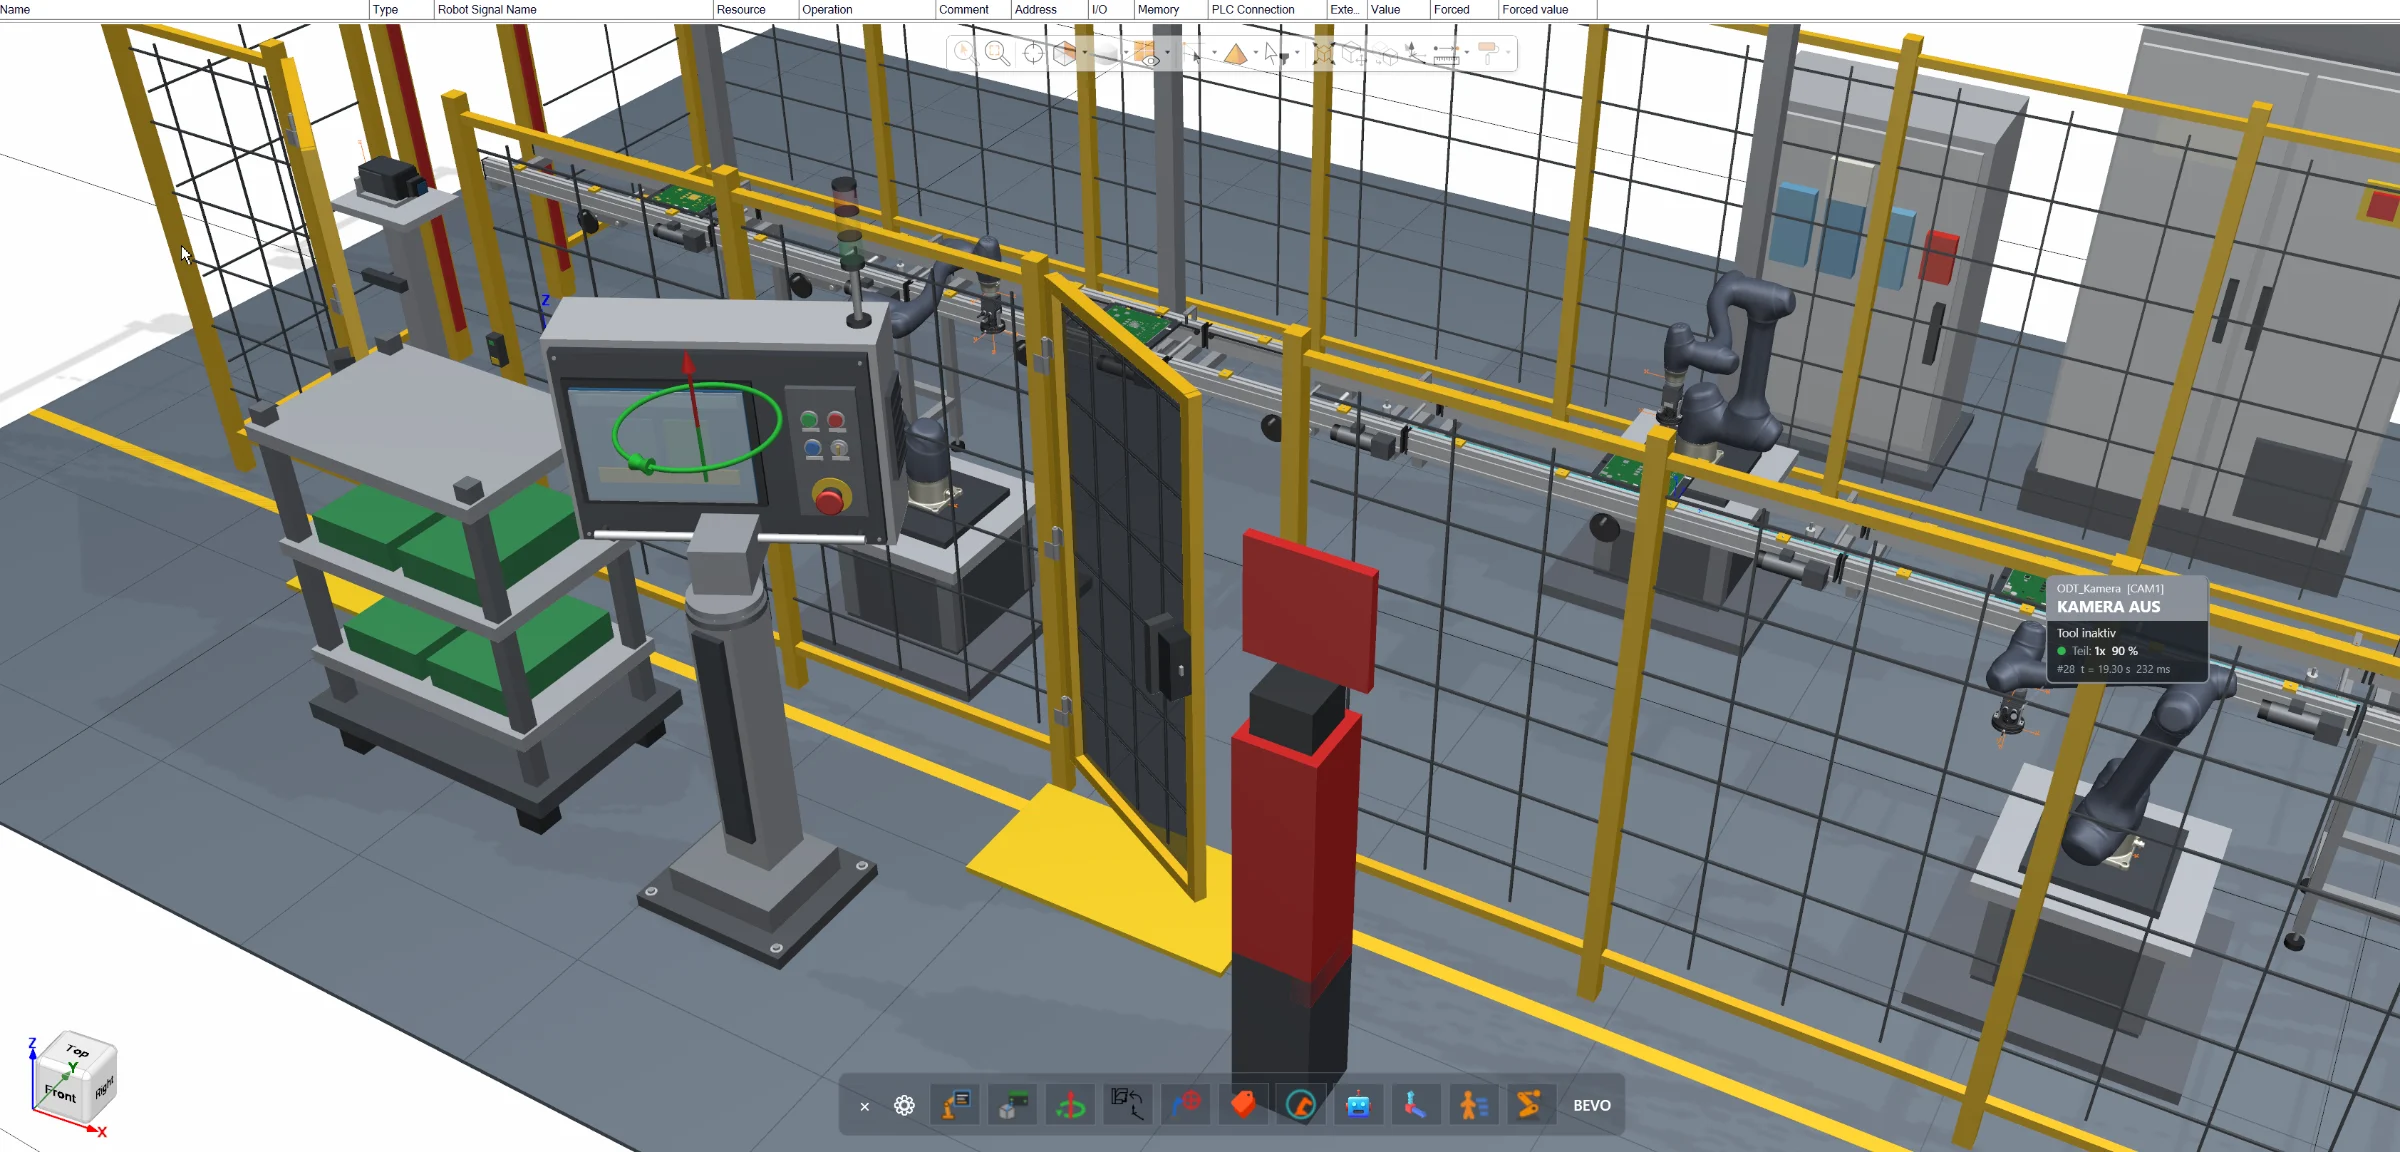
Automated conversion of existing Process Simulate Standalone, PSZ and EMS cell structures into Process Simulate in Teamcenter, including geometry, kinematics, robot paths, motion volumes, classes and object types.